

by Mat Dirjish
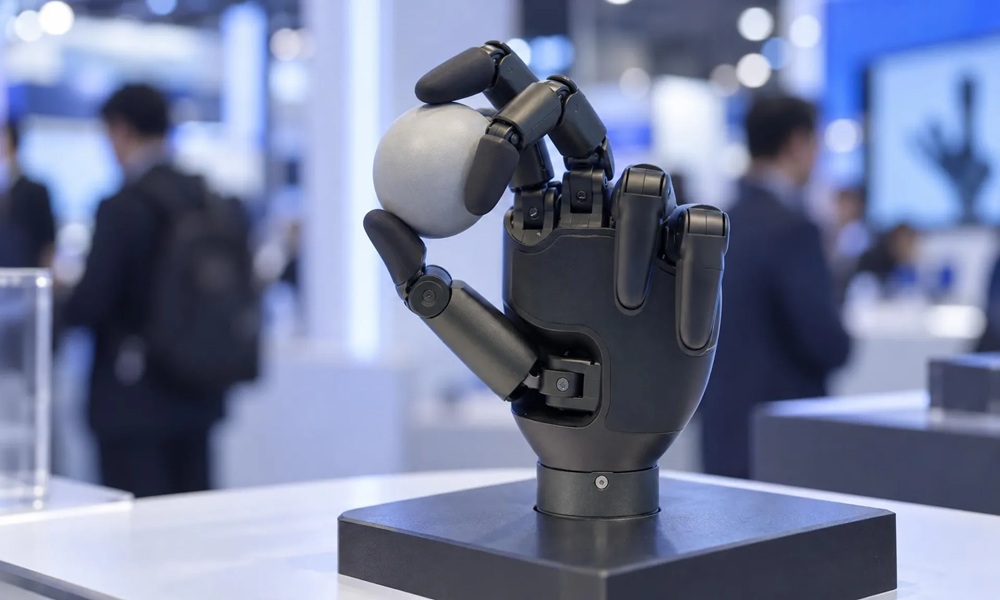
Debuting at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), DH-Robotics’ ADH-5-13 five-finger dexterous hand offers 13 independently controllable active degrees of freedom (DOF). The robotic hand uses an anthropomorphic five-finger configuration whereby the thumb, index, and middle fingers each have three DOF and the ring and little fingers each have two. The index and middle fingers also provide ±15° of lateral motion, enabling a wide range of multi-finger poses.
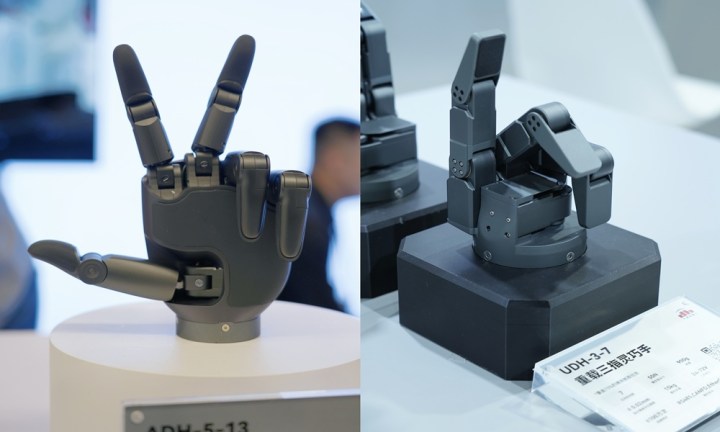
Weighing 735g, the hand promises to balance dexterity with system weight. Maximum lifting payload is up to 20 kg once the hand grasps an object. It also integrates fingertip tactile sensing and can accommodate additional sensing options including electronic skin, six-axis force/torque sensors, and vision-based tactile sensors. For servicing and maintenance, sensors and individual modules are replaceable without dismantling the hand or a finger.
Other ADH-5-13 features include:
- A direct-drive, back-drivable architecture that provides independent control of all 13 DOF while supporting hybrid force/position control and compliant contact behavior in manipulation tasks.
- Dual magnetic encoders at each joint provide position feedback.
- A fingertip positioning repeatability of ±0.2 mm.
- Maximum fingertip force of 50 N.
- An operational life of one million cycles.
- Thumb supports a 180° range of rotation and opposition.
Additionally, the UDH-3-7 supports CAN FD, RS-485, and EtherCAT while its development tools support C++ and Python. For greater gleanings, visit the DH-Robotics website.

